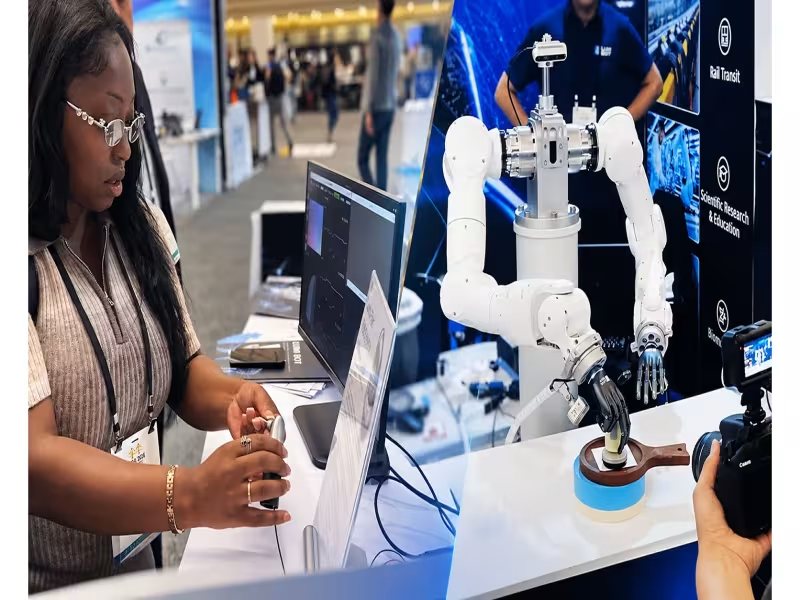
Pittsburgh – September 30, 2026 -- LumiBot, a robotics startup founded just over a year ago and known in China as Shiyue Technology, unveiled a full stack of finger-shaped visuo-tactile sensors, dexterous hand hardware and manipulation foundation models at IROS 2026, where it was also selected to present at the conference's official Startup Session.
Industry-wide tactile datasets total only tens of thousands of samples, LumiBot says
The company argues that embodied AI's progress is capped by a hardware bottleneck: public multimodal datasets combining high-DOF dexterous hands with tactile feedback number only in the tens of thousands of samples, while scalable manipulation models require tens of millions of hours of real-world operational data. LumiBot's strategy is to fix data quality at the hardware layer so collected samples are standardized and reusable from the outset.
New micro joint module targets over 5,000 hours of continuous operation
The Lumi-Dex hand series supports mainstream industrial communication protocols and integrates across robotic arm platforms and simulation environments. At the show, LumiBot demonstrated its Lumi-Dex-21 high-DOF hand, which combines linkage and direct-drive mechanisms in a single drive-control unit. An upcoming flagship hand, powered by a self-developed active-cooling micro joint module, is designed to hold operating temperatures near 50°C and sustain more than 5,000 hours of continuous no-load operation, enabling weeks of uninterrupted data collection.
Lumi-Tac V2 sensor hits 10-micron resolution and 0.02 N force accuracy
The Lumi-Tac visuo-tactile sensor V2 extends coverage across the fingertip, finger side and finger pad, with a 10-micron spatial resolution, 0.02 N force detection accuracy and a 120 fps frame rate. Paired with proprietary curved-surface reconstruction algorithms, the sensor is built to generate high-information-density tactile streams for model training.
Ego-to-robot mapping achieves millimeter-level precision in verification tests
LumiBot has operationalized a real-robot teleoperation pipeline for continuous data gathering, alongside an egocentric (Ego) data-to-robot mapping scheme verified at millimeter-level precision. On the model side, the Lumi-Mind manipulation foundation model uses a hierarchical Mixture of Transforms architecture fusing vision, tactile, language and action modalities, with a memory mechanism and tactile gating for long-horizon planning and fine contact adjustments. The proprietary Lumi-Cap pipeline links Ego video capture, teleoperation data and automated cleaning into a closed capture-train-deploy-feedback loop.
Constrained-DOF hand completes six-step task sequence under live disturbance
In a live demonstration, LumiBot's lower-DOF Lumi-Dex-11 hand, driven by the Lumi-Mind model, executed a sequence of picking up a stamp, stamping, picking up a tray, handing out a card, and returning both items. When human disturbances were introduced mid-task, the model re-evaluated and adjusted its plan in real time.
LumiBot runs proof-of-concept trials in automotive, 3C electronics and life sciences
Founded in 2025, LumiBot has built its entire stack in-house, spanning motors, visuo-tactile sensors, dexterous hands, manipulation models and data acquisition pipelines. The company is currently advancing scenario validation and technical proof-of-concept programs with industry players in automotive manufacturing, 3C electronics and life sciences, testing the scale-up capability and reliability of its hardware and systems in production environments.